RoboBin Physical & Fabrication Metrics
Derived geometric properties from 3D tessellation and laser cutting CAM layout for the autonomous mobile waste sorting airframe.
Laser Cutting Profiles & Part Dimension Callouts
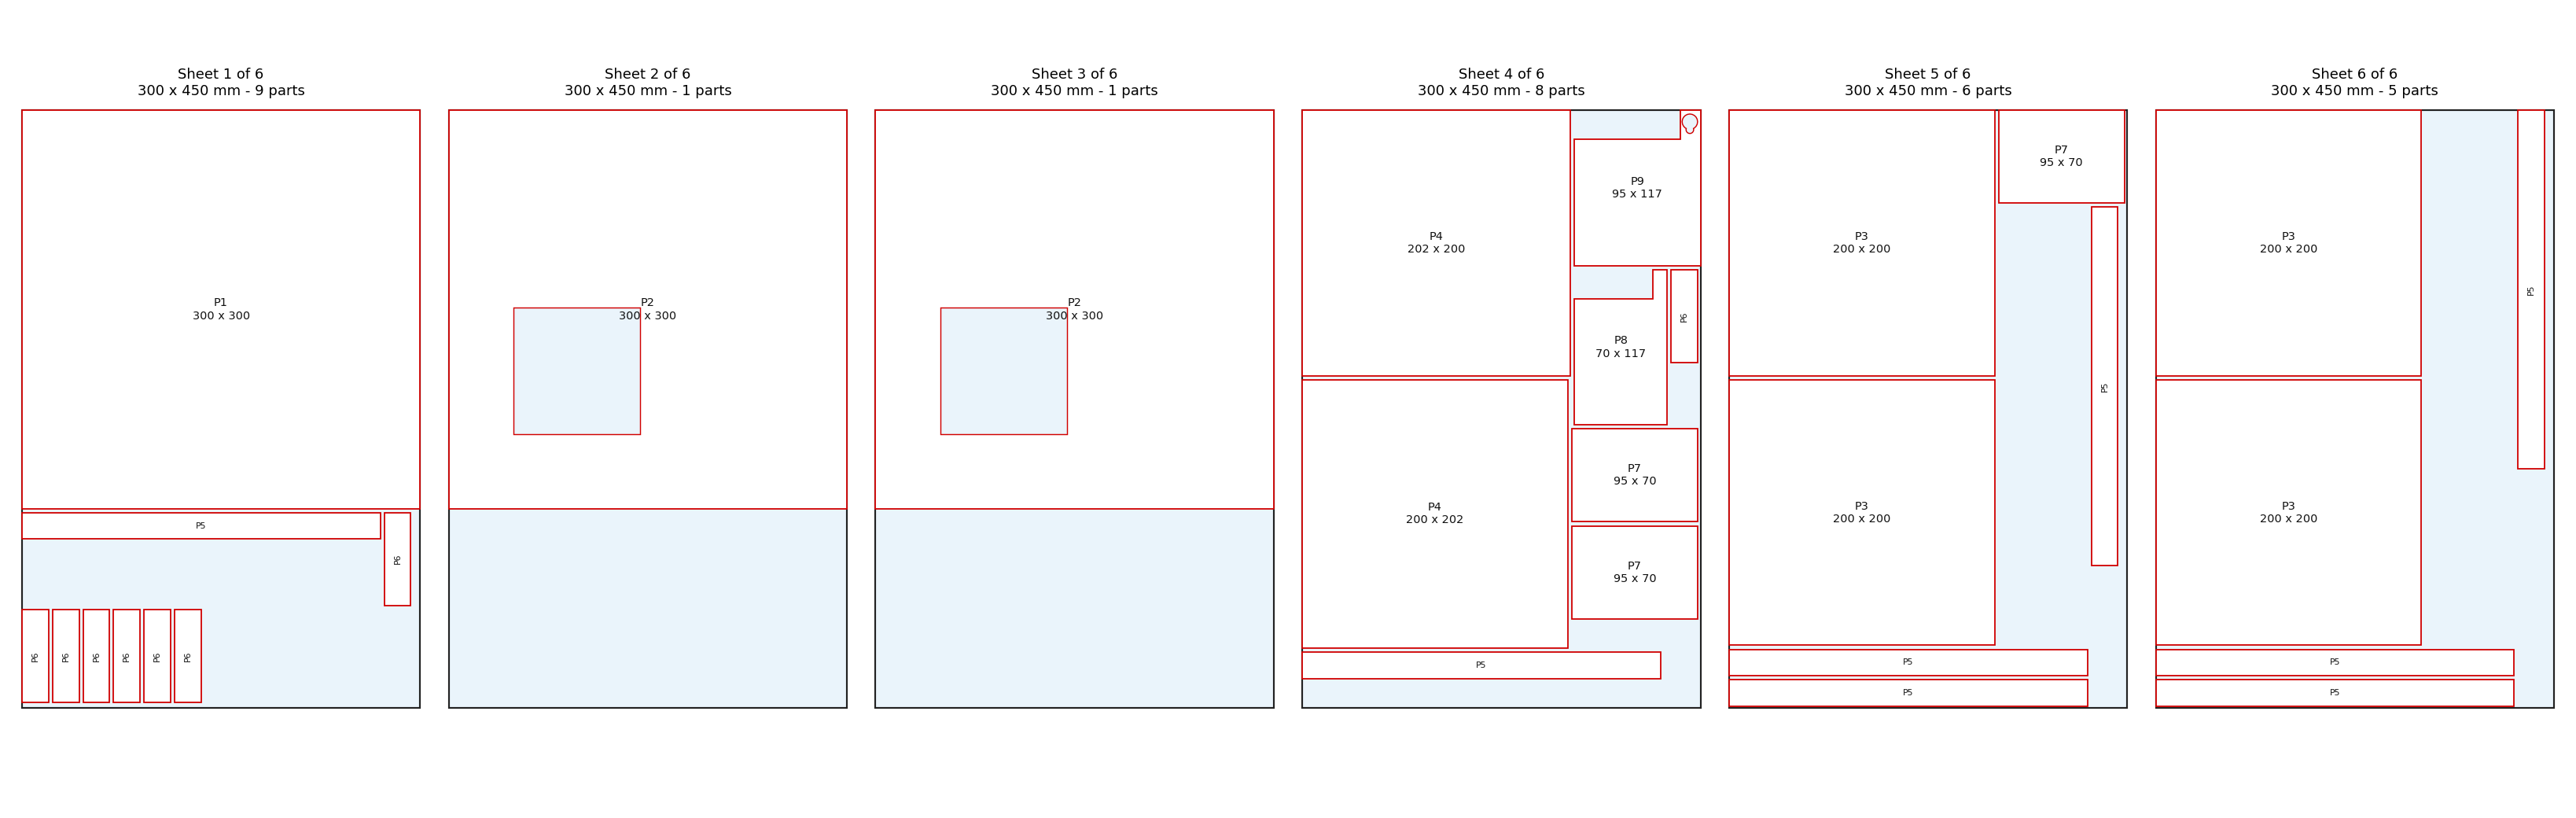
Strictly black and white vector engineering drawings for all 6 acrylic sheets (300 × 450 mm). All part outlines feature annotated dimension callouts. Hover on any part to inspect component telemetry.
Complete 6-Sheet Nesting Plan
Global manufacturing overview showing the 30 components nested across six 300 × 450 mm raw acrylic stock sheets with 3 mm inter-part separation.
Autonomous Hospital AGV Dispatch & Route Simulator
Interactive clinical ward spatial simulator demonstrating autonomous navigation between patient beds, closed-loop MPU6050 turn maneuvers, and real-time UART serial telemetry execution.
4-Quadrant Rotary Carousel & Intake Hatch Geometry
Technical schematic of the internal rotary carousel drum (Ø 280 mm). The 4-quadrant acrylic partition isolates recyclables, organics, medical sharps, and biohazard waste beneath the 95 × 95 mm intake chute.
4-Phase Engineering & Implementation Roadmap
Phased development plan decoupling mechanical fabrication, embedded motor control, Edge AI classification, and clinical navigation.
- Arduino Uno + Dual DC Motors
- MPU6050 IMU gyro yaw stabilization
- HC-05 with 5V-to-3.3V resistor divider
- Independent motor battery supply
- MG995 metal gear carousel servo
- Secondary hatch trapdoor servo
- Dedicated 5V 3A isolated buck converter
- Calibrated 4-quadrant angles (~60° separation)
- Raspberry Pi 3B+ + Pi Camera
- Quantized MobileNet INT8 TFLite model
- Internal chute LED ring illumination
- Hands-free B1–B4 command dispatch
- Hospital grid layout route planner
- Sequential F / L / R command buffering
- Pi 3B+ Wi-Fi access point bridge
- HC-SR04 ultrasonic collision cutoff